
AGR Group factory production
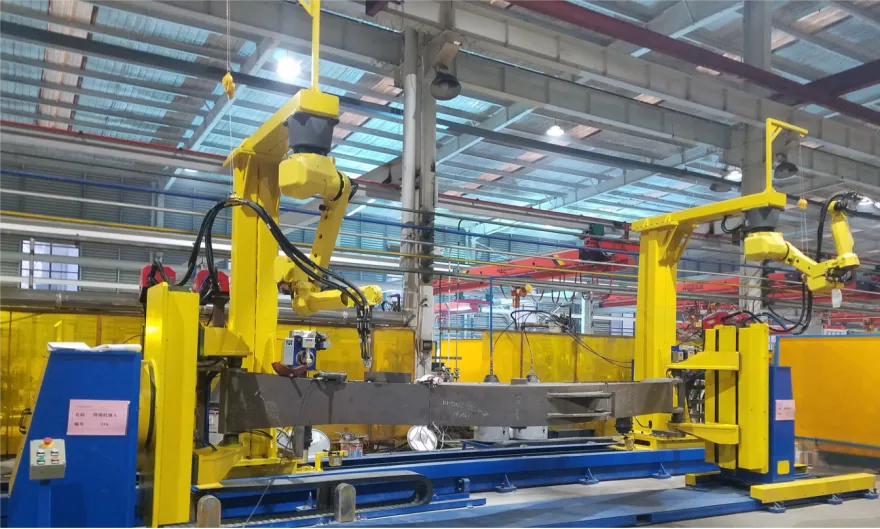
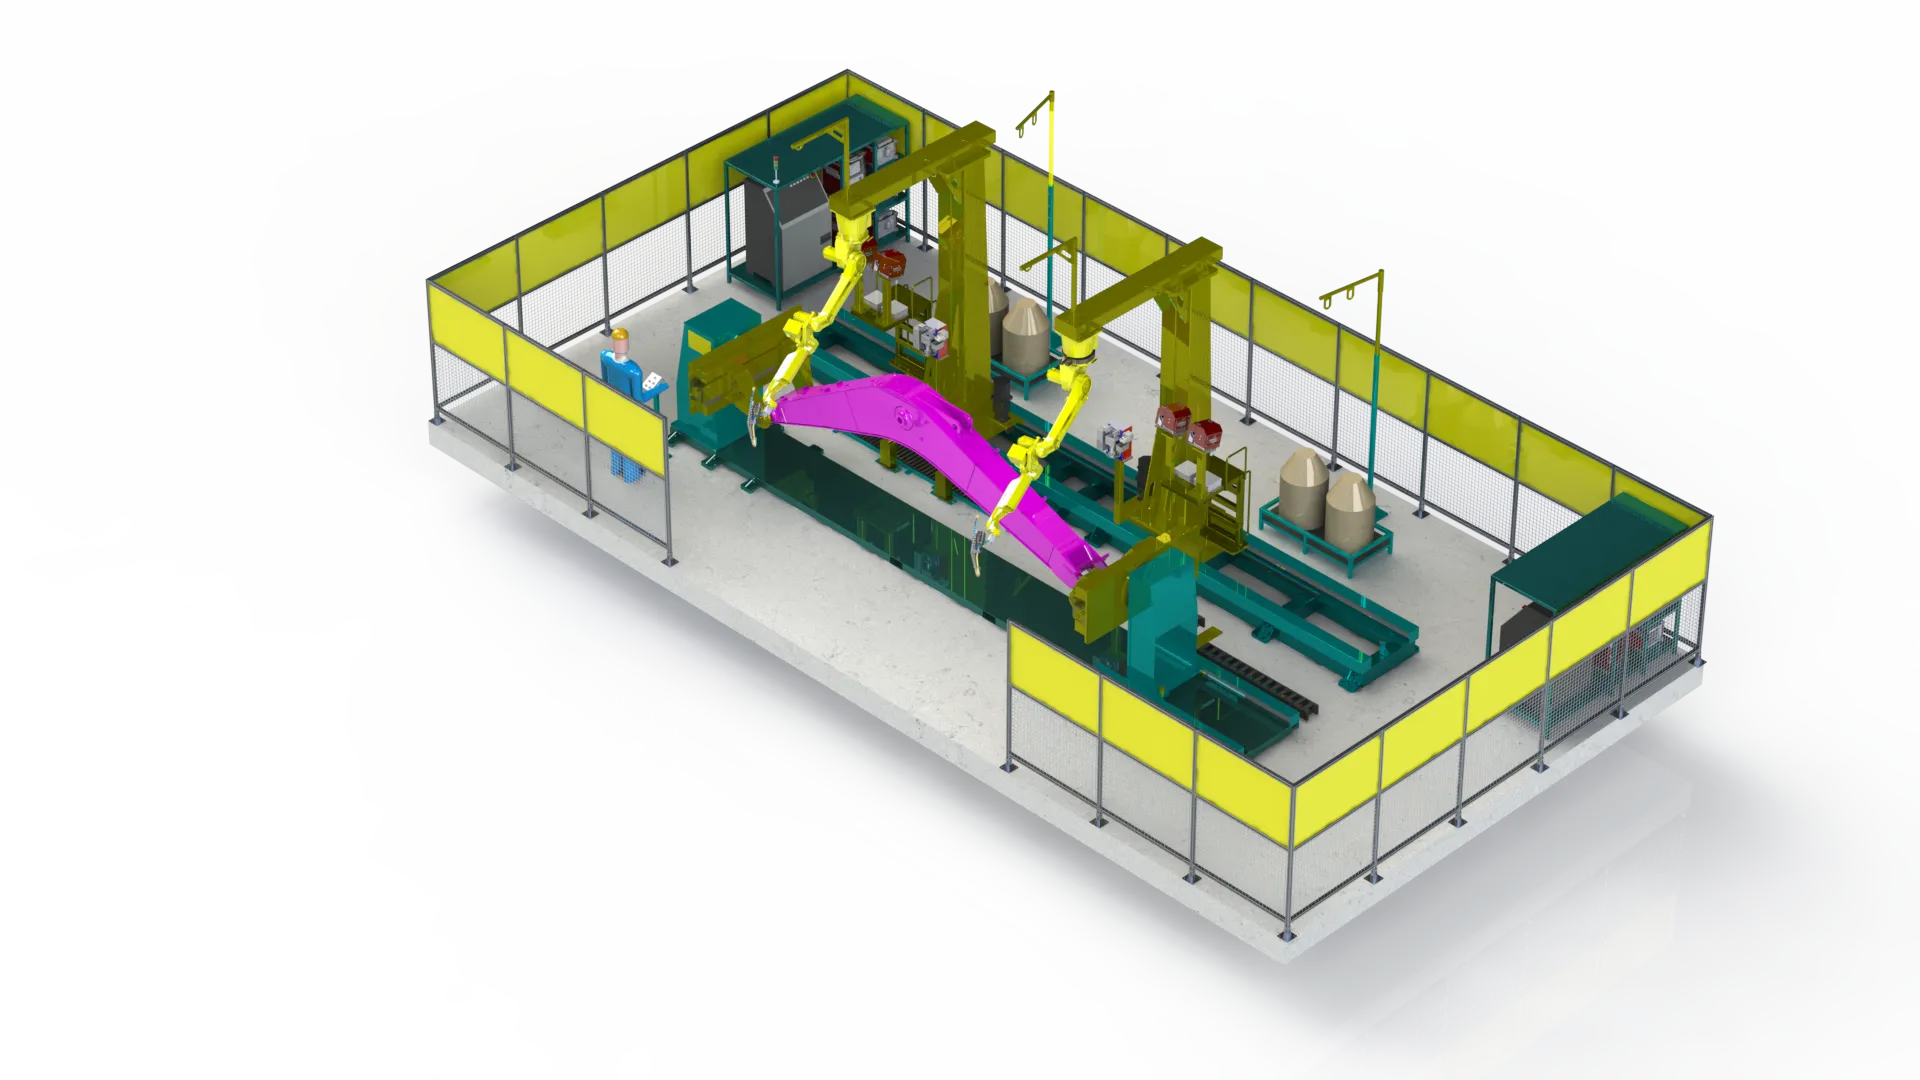
Dual-Robot Coordinated Welding Cell for Excavator Booms
Factory production cell using coordinated dual-robot welding for excavator boom structures.
This is an in-production AGR Group factory application.

Workpiece
Hydraulic-excavator boom.
Production Challenge
2 robots had to execute coordinated welding reliably within a shared working envelope.
AGR Solution
The workstation uses coordinated motion between 2 arc-welding robots, a welding-parameter library, and bus communication between the robots and welding power sources.
System Configuration
2 arc-welding robots, coordinated motion, welding-parameter library, robot/power-source bus communication, and coordinated control in a shared working area.
Implementation
Applied in production at an AGR Group structural-parts factory.
Case Results
2-robot coordinated welding is operated in the factory.
Application Conditions
Similar boom-welding applications can be assessed.
Engineering Highlights
- Coordinated motion between 2 robots
- Welding-parameter library
- Bus communication between robot and welding power source
- Coordinated operation in a shared working area
Media & System Views
Discuss a Similar Application
Drawings, workpiece photos, material, plate thickness, production volume, and current process help us make an initial assessment.
Discuss Your Application